Humanoid Robot End Effector Components
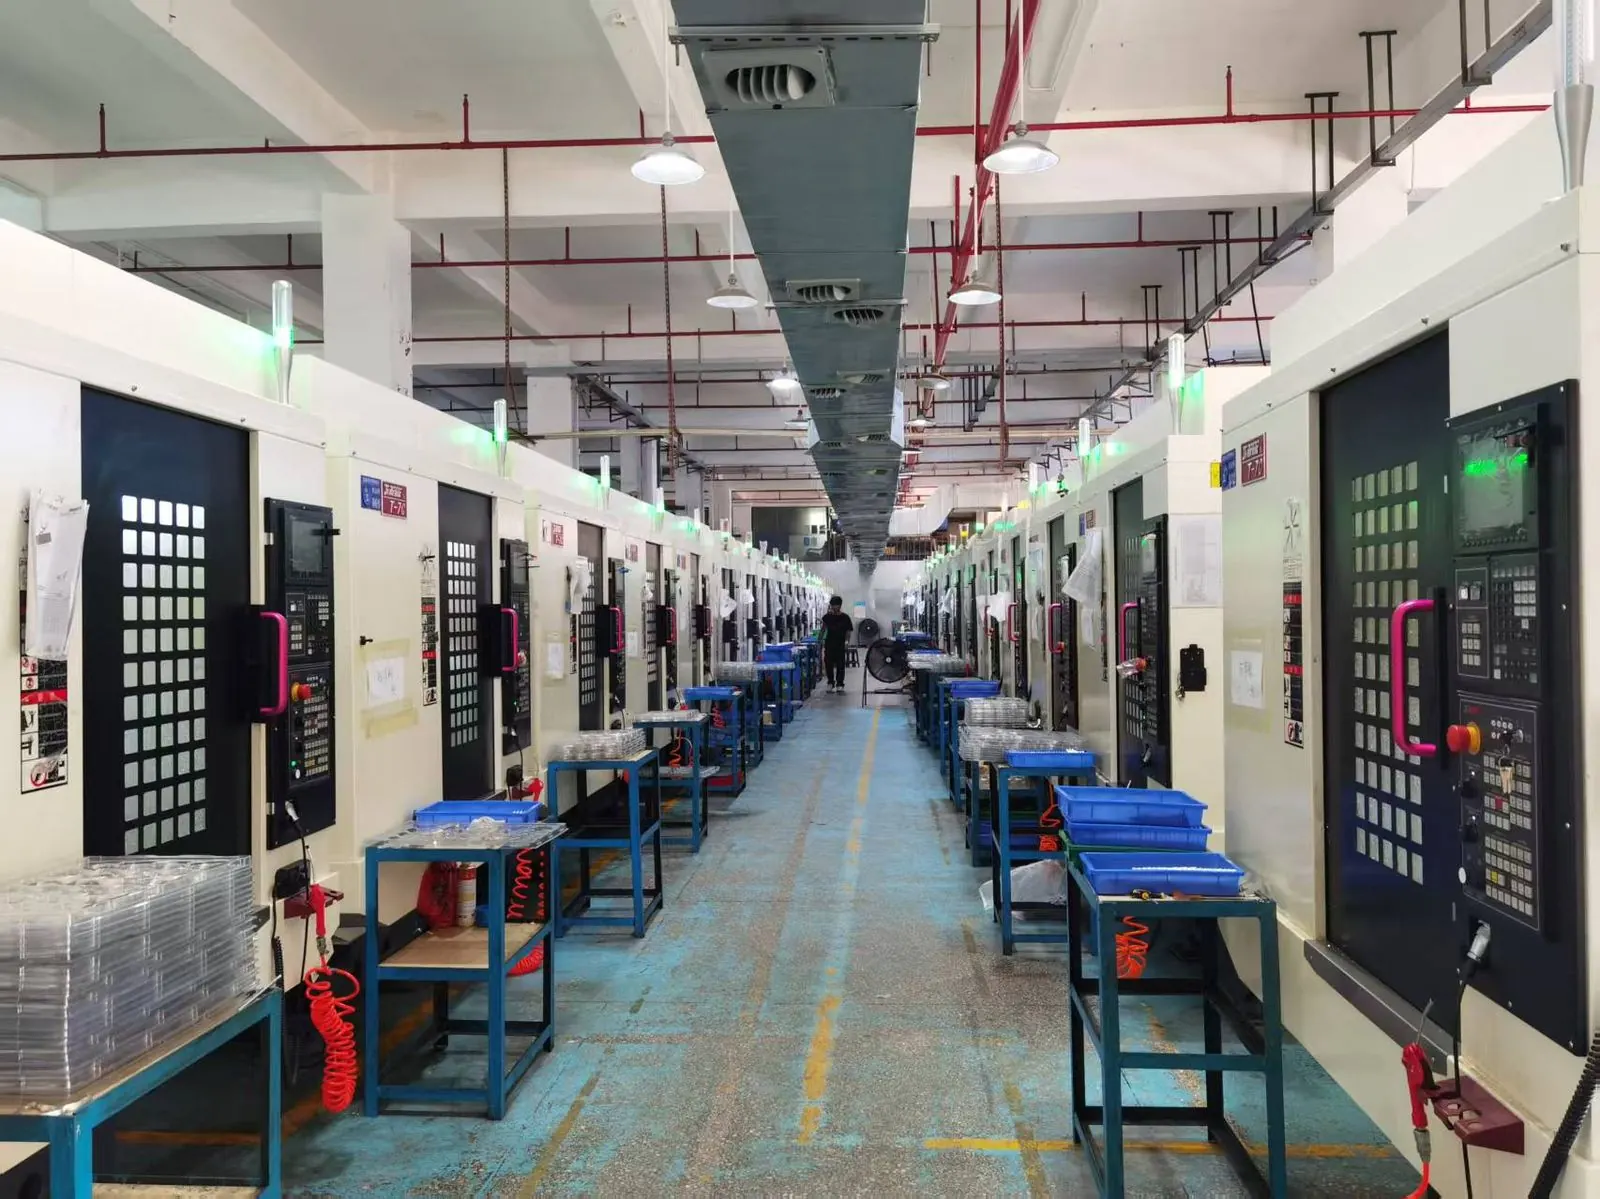
Gripper Jaws • Wrist Modules • Tool Changers • ±0.005mm • 220 CNC Machines
 Get a Quote
Call +86 181-3885-0989
CNC machined humanoid robot end effectors — gripper jaws, wrist modules, tool changers, force-torque sensor housings. ±0.005mm. 220 CNC machines. ISO 9001. CHX Metal supports customers from prototype to mass production and ships to more than 50 countries.
Why CHX Metal for Humanoid Robot End Effectors
An end effector is the interface between robot and reality — the gripper, suction cup, tool holder or specialized tool that actually performs the work. We manufacture the precision components that make humanoid robots functional in factories, warehouses and homes.
- Parallel gripper jaw machining — precision gripper jaws with anti-slip serrations and soft-pad mounting features.
- Tool changer (ATC) components — standardized ISO 9409-1 flange, locking mechanism and taper pins.
- Vacuum gripper suction cup holders — smooth sealing surfaces with integrated vacuum channels.
- Force-torque sensor housings — stiff, lightweight housings for 6-axis F/T sensors.
- End-effector cable management — integrated cable channels, strain reliefs and connector brackets.
Humanoid Robot End Effector Applications
Two-Finger Parallel Gripper
Industrial pick-and-place grippers for bin picking, assembly and packaging.
Three-Finger Centric Gripper
Centric grippers for cylindrical objects such as bottles and shafts.
Magnetic Gripper Housing
Permanent-electromagnet housing for ferrous material handling.
Compliant / Soft Gripper
Flexible gripper components for delicate items such as fruit, eggs and electronics.
Multi-Tool Changer
Quick-change end-effector systems for multi-task robots.
Specialized Tool Holder
Custom end-of-arm tools for welding, dispensing and testing.
Materials & Tolerances
Materials selected for grip reliability and durability:
- 6061-T6 Aluminum — lightweight and easy to anodize; the most common gripper body.
- 7075-T6 Aluminum — high-stress structural grippers and tool changers.
- 304 / 316 Stainless Steel — food-grade and washdown environments.
- Engineering plastics (PEEK, POM, Nylon) — soft-touch contact surfaces.
- Tool steel (D2, H13) — high-wear gripper jaws for production volumes.
Tolerances: ±0.005mm standard, ±0.005mm on alignment-critical features. Surface finish: as-milled Ra 1.6 or better, with Type III hardcoat anodizing for wear surfaces.
Frequently Asked Questions
What is the MOQ for custom end-effector parts? 1 piece for prototyping. We support both small-batch prototyping and mass production on the same equipment.
Can you hold ±0.005mm on gripper alignment features? Yes, on features up to 200mm. We use CMM verification for the first article and in-process gauging for production runs. ±0.005mm is standard for gripper alignment dowels and locating features.
Do you offer gripper jaw surface treatments? Yes — Type III hardcoat anodizing (60+ µm) for aluminium jaws, electroless nickel for steel and DLC coating for titanium. We also produce soft-pad gripper jaws with replaceable rubber or silicone pads.
Can you produce tool changer components to the ISO 9409-1 standard? Yes — we produce tool changer flanges, taper pins and locking mechanisms to ISO 9409-1-50-4-M6 and other variants. Specify your robot model and we will match the standard.
Need Humanoid Robot End Effectors? Get a Quote in 24 Hours.
Upload your drawing (PDF, STEP or SolidWorks). Free DFM feedback.
Request a Quote →