Robot Hand Joint Components for Humanoid Robots
Crossed-Roller Joints • Strain-Wave Gear Housings • ±0.005mm Precision • 7075-T6 Aluminium / Titanium
 Get a Quote
Call +86 181-3885-0989
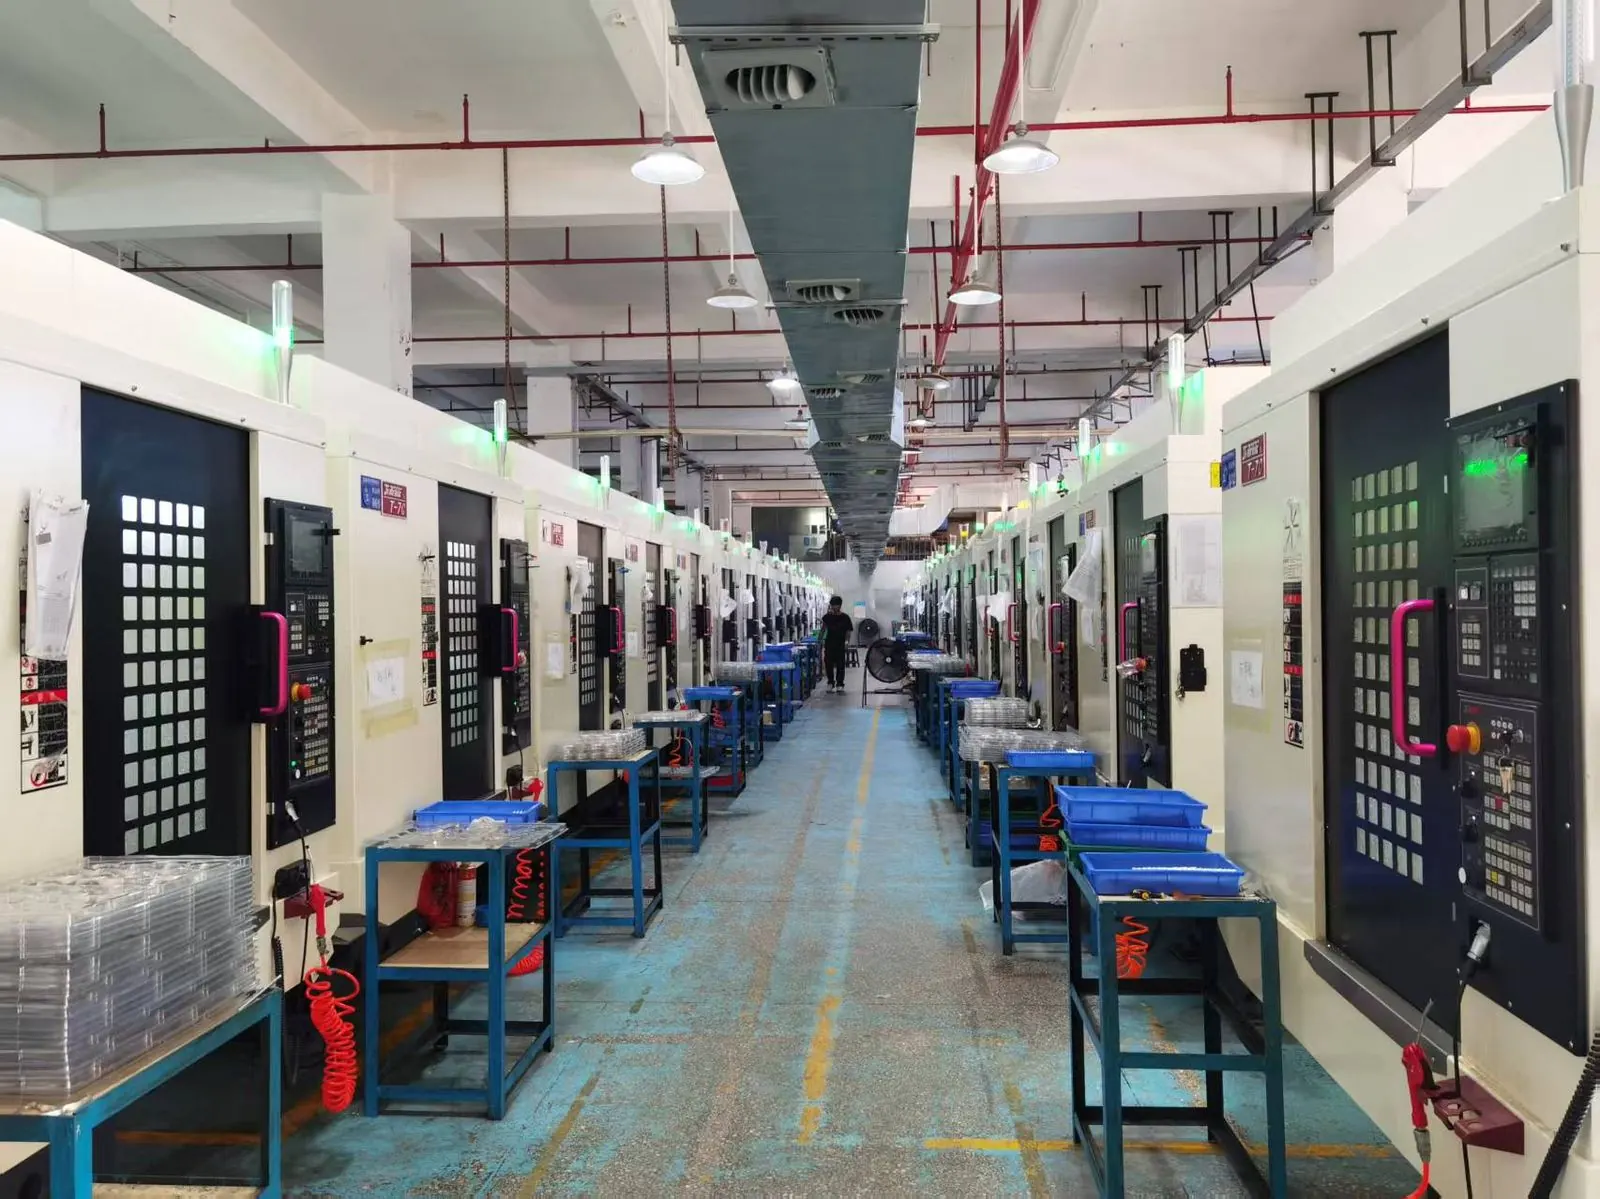
CNC machined robot hand joints for humanoid robots. Crossed-roller bearings, strain-wave gear housings, ±0.005mm. 7075-T6 aluminium and titanium. CHX Metal runs 220 CNC machines in Shenzhen, including Swiss-type lathes and 5-axis machining centres.
Why CHX Metal for Robot Hand Joints
Humanoid robots require high-precision hand joints with very tight tolerances, low backlash and excellent wear resistance. We machine the structural housings, output flanges, wave-generator cups and bearing races that sit inside high-dexterity robotic hands.
- Strain-wave gear component machining — flexspline cups, wave generator bearings and circular spline flanges.
- Output flanges with integrated splines — involute splines, double-D and proprietary drive profiles.
- Titanium Grade 5 (Ti-6Al-4V) and Grade 2 (CP-Ti) — lightweight, biocompatible and high fatigue life for premium joints.
- Surface treatments for wear resistance — anodizing, DLC coating preparation, electroless nickel and nitriding.
- Concentricity control — bearing seats verified within 0.005mm TIR and documented in the FAI report.
Robot Hand Joint Applications
Dexterous Hand Finger Joint
Single-axis finger joints with crossed-roller bearings for 16–22 DOF humanoid hands.
Wrist Joint (Pitch / Yaw / Roll)
Three-axis wrist modules with a central through-bore for cable routing.
Elbow Joint Module
High-torque elbow joints with integrated strain-wave reduction.
Shoulder Joint (3-DOF)
Multi-axis shoulder modules combining pitch, yaw and roll in a compact envelope.
Thumb Opposition Joint
Specialized opposable thumb joints for human-like grip patterns.
Force / Torque Sensor Housing
Stiff aluminium housings for 6-axis F/T sensors at the wrist.
Materials & Tolerances
Optimized for high strength-to-weight ratio and biocompatibility:
- 7075-T6 Aluminium — excellent strength-to-weight ratio; cost-effective for production volumes.
- Ti-6Al-4V (Grade 5 Titanium) — high strength, biocompatible and fatigue resistant.
- CP Titanium Grade 2 — corrosion-resistant for medical and collaborative robot use.
- 17-4 PH Stainless Steel — high stiffness for precision bearing seats.
- PEEK / PI (polyimide) — polymer options for low-friction contact surfaces.
Concentricity: within 0.005mm on bearing seats. Flatness: 0.005mm / 100mm on mating flanges. Surface finish: Ra 0.4 µm on bearing contact surfaces.
Frequently Asked Questions
Can you match the precision of strain-wave gear manufacturers? We hold ±0.005mm on features up to 150mm — sufficient for the structural components around strain-wave gears. Final gear grinding is performed by specialized suppliers.
What is your experience with humanoid robot projects? We have supported robotics developers since 2018 with dexterous hand subassemblies, collaborative robot arm joints and humanoid torso/limb prototypes.
Do you machine both small-batch prototypes and volume production? Yes — MOQ 1 piece for prototypes, scaling to 500+ pieces per month for production, on the same equipment and quality system.
What surface treatments do you recommend for joint wear surfaces? Aluminium: Type III hardcoat anodizing (60+ µm). Titanium: DLC coating or nitriding. Steel: electroless nickel with PTFE, or black oxide.
Need Robot Hand Joints? Get a Quote in 24 Hours.
Upload your drawing (PDF, STEP or SolidWorks). Free DFM feedback.
Request a Quote →