Robot Fingertip Covers & Tactile Sensor Pads
Dexterous Hand End Caps • Silicone-Ready Surface • ±0.005mm Profile • 7075 / PEEK / POM
 Get a Quote
Call +86 181-3885-0989
CNC machined robot fingertip covers and tactile pads. Silicone-compatible housings with smooth finishes for tactile sensors. 7075 aluminium, PEEK, POM. Engineering teams review drawings and return manufacturability feedback within 24 hours.
Why CHX Metal for Robot Fingertip Covers
The fingertip is the most frequently touched surface on any humanoid robot — it makes contact with every object the robot manipulates. We manufacture precision fingertip housings that integrate with capacitive, resistive, optical or piezoelectric tactile sensors.
- Tactile sensor integration — cavities and channels for FPC cable routing and PCB mounting.
- Soft-tip molding compatibility — surfaces designed for direct silicone overmolding (Shore 10–30A).
- Material choice — 7075-T6 aluminium, POM, PEEK, ABS and polycarbonate, including grades suitable for medical applications.
- Surface textures — knurled, ribbed or smooth options for grip enhancement on smooth objects.
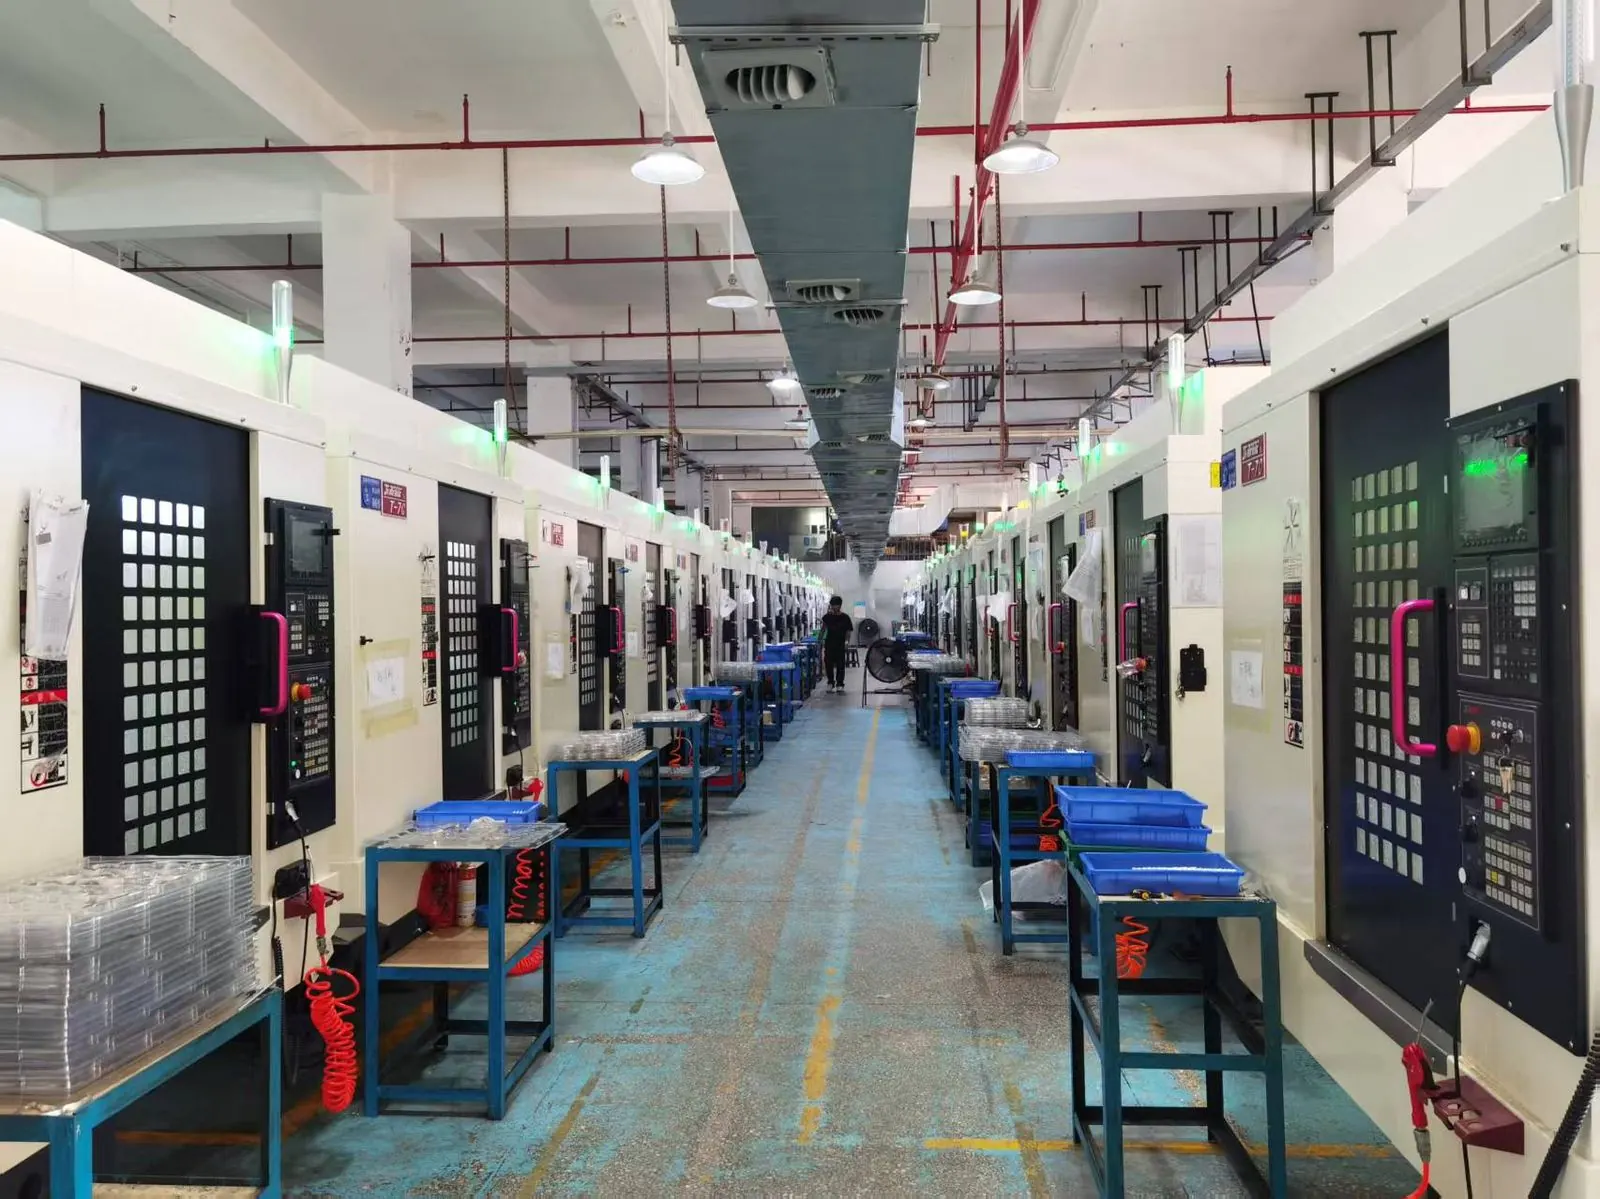
- Batch consistency — 5-axis machining with on-machine probing and CMM verification of the contact profile.
Robot Fingertip Cover Applications
Capacitive Tactile Sensor Pad
Insulated fingertip covers for capacitive touch and pressure sensing arrays.
Optical Tactile Sensor Cover
Clear or translucent covers for camera-based optical tactile sensors.
Force-Sensitive Resistor Cover
Protective outer shells with embedded FSR sensing elements.
Pneumatic Soft Tip
Rigid inner core with channels for pneumatic soft-tip actuation.
Heat-Resistant Gripper Pad
High-temperature resistant covers for hot-object manipulation.
Tool Changer Adapter
Standardized fingertip ends for quick-change end-effector systems.
Materials & Tolerances
Choose the right material for your tactile sensing method and use case:
- 7075-T6 Aluminium — rigid and conductive; requires an insulation layer for capacitive sensors.
- PEEK — biocompatible, autoclavable, heat-resistant up to 250 °C; for medical and food-grade robots.
- POM — low friction and low moisture absorption; general purpose.
- ABS / Polycarbonate — low cost, easy to post-process and impact resistant.
- Aluminium + silicone overmold — rigid core with a soft exterior for delicate object handling.
Profile tolerance: ±0.005mm general, ±0.005mm on the contact surface. Surface finish: Ra 0.8–1.6 µm standard, down to Ra 0.4 with a finishing pass.
Frequently Asked Questions
Which materials are suitable for capacitive tactile sensor covers? Insulating materials such as PEEK, POM, ABS or polycarbonate are required. For metal-tip capacitive sensing, a thin dielectric coating (0.1–0.5mm) is applied over the aluminium surface.
Can you match the curved surface of an existing fingertip design? Yes — send us your 3D model (STEP / IGES / X_T) and we will machine a matching cover. We produce drop-in replacements for common dexterous hands.
What is the lead time for 50 robotic fingertips? 7–10 business days for prototype runs (1–20 pcs) and 15–20 business days for low-volume production (50–200 pcs). High-volume runs (1000+) take 20–30 days.
Do you offer soft-tip (silicone) fingertips? We machine the rigid inner core; silicone overmolding is carried out by an audited partner. We can also supply the complete assembly if you prefer turnkey delivery.
Need Robot Fingertip Covers? Get a Quote in 24 Hours.
Upload your drawing (PDF, STEP or SolidWorks). Free DFM feedback.
Request a Quote →