Humanoid Robot Finger Parts
Finger Joints • Fingertips • Knuckle Brackets • Sensor Pads • ±0.005mm
 Get a Quote
Call +86 181-3885-0989
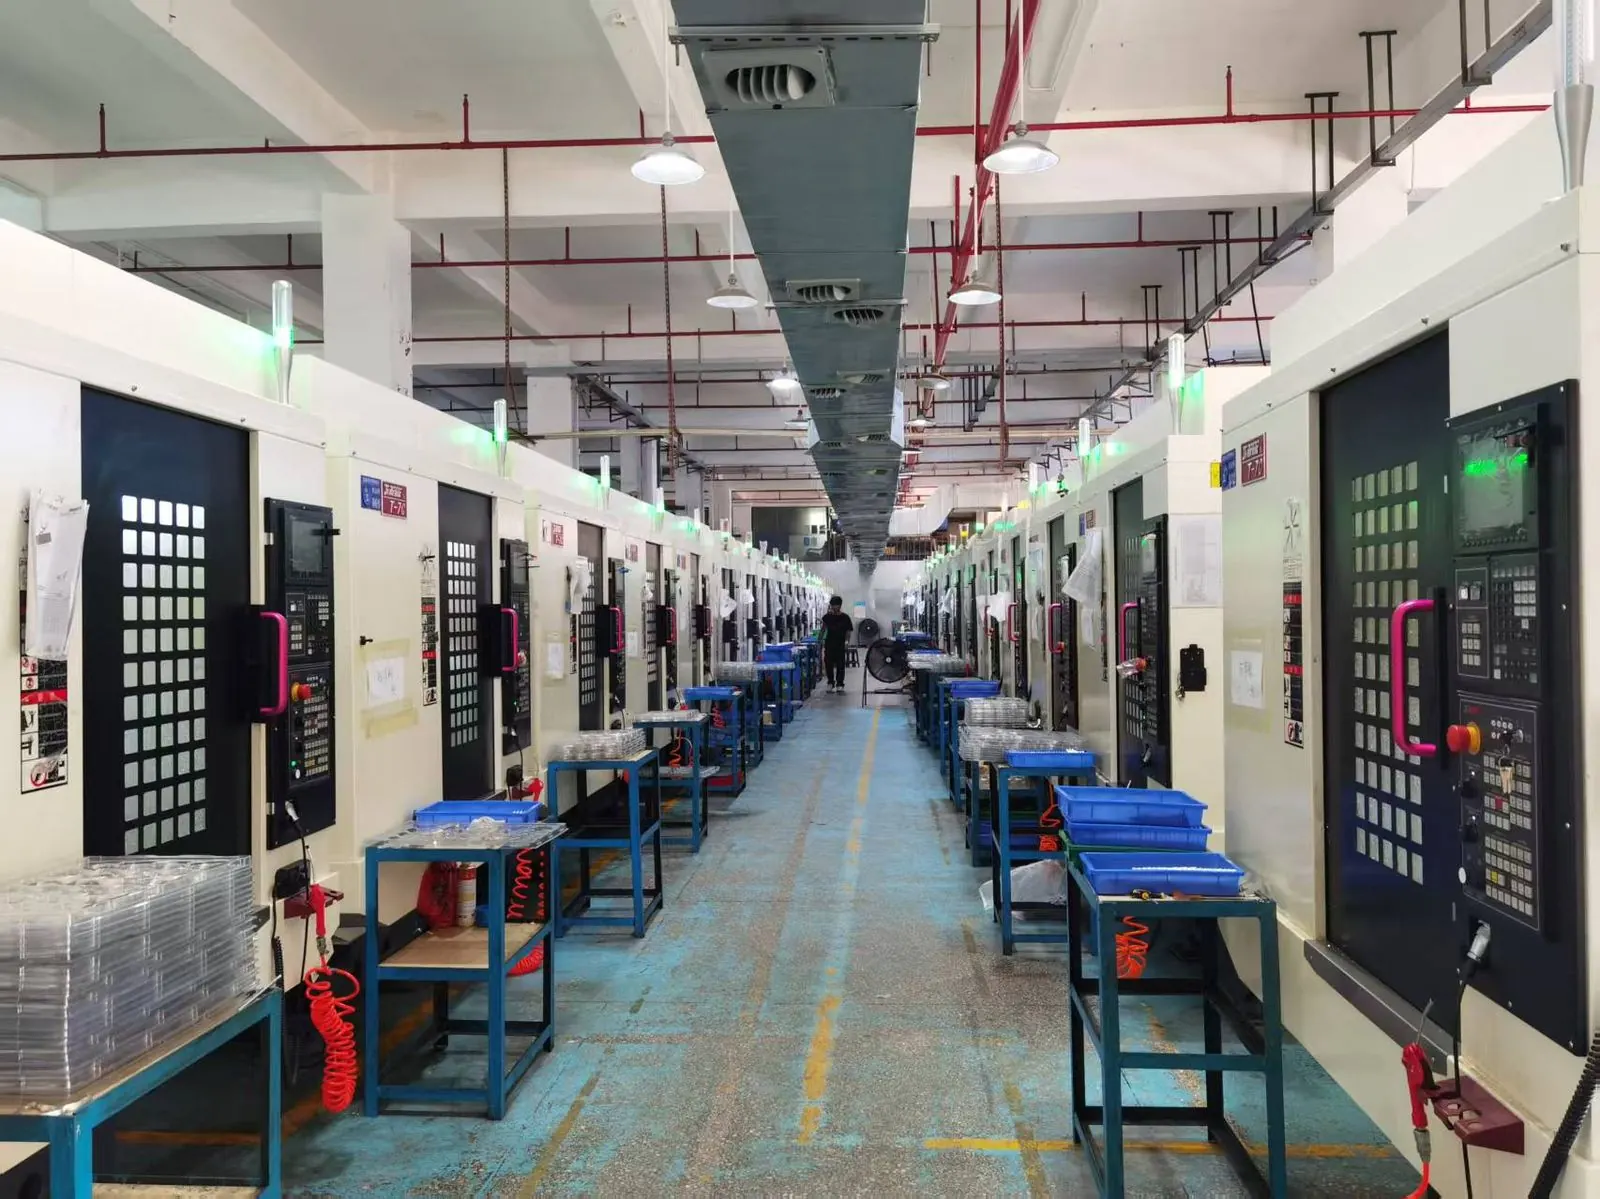
CNC machined humanoid robot finger parts - finger joints, fingertips, knuckle brackets and sensor pads. 7075 aluminium, TC4 titanium, PEEK. ±0.005mm, ISO 9001. The factory covers 5,000 m2 and produces up to 5 million precision parts per month.
Why CHX Metal for Humanoid Robot Finger Parts
The finger is the most densely packed assembly on a humanoid robot: a joint housing, a tip, a pad, a linkage guide and a sensor carrier all fit inside a few tens of millimetres. We machine these parts as one coordinated set so that the joint axes, sensor windows and tendon paths line up on assembly instead of being reworked on the bench.
- Finger joint housings — pivot bores, bearing seats and gear pockets held on one datum for repeatable assembly.
- Fingertips and finger caps — thin-wall shells with sensor windows and friction surfaces.
- Knuckle and pivot brackets — cross-roller and harmonic-drive interfaces, machined as matched pairs.
- Linkage and tendon guides — internal channels for cables, tendons or push rods, deburred and radiused.
- Sensor and FPC carriers — cavities and slots sized for flexible printed circuits and tactile arrays.
Where These Finger Parts Are Used
Dexterous robot hands
Multi-jointed hands with 3 to 5 fingers per hand for research and service robotics.
Bipedal humanoid platforms
Upper-limb assemblies where finger mass directly affects payload and battery life.
Collaborative grippers
Two- and three-finger grippers that need repeatable finger alignment.
Prosthetic hand frames
Lightweight structural finger frames that accept commercial actuators.
Humanoid R&D prototypes
Small-batch finger sets for design iterations and lab testing.
Materials & Tolerances
Finger parts are selected for the balance of mass, stiffness and wear resistance the joint needs:
- 7075-T6 aluminium — the default for finger links and brackets where stiffness per gram matters.
- TC4 (Grade 5) titanium — for high-load knuckles and parts that must survive repeated impact.
- 304 / 316L stainless steel — pivot pins, shafts and wear surfaces.
- PEEK, POM and PI (polyimide) — insulating carriers and low-friction pads.
Tolerances: ±0.005 mm on joint bores and gear seats, ±0.005 mm general. Surface finish: Ra 0.8 or better on bearing fits, Type II anodising or hard anodising on aluminium wear faces.
Frequently Asked Questions
What tolerance can you hold on finger joint bores? ±0.005 mm on bores up to 50 mm, and ±0.005 mm on positioning features up to 200 mm. First articles are verified on a coordinate measuring machine and dimensions are recorded in an inspection report.
Which materials do you recommend for finger links? 7075-T6 aluminium for most links, TC4 titanium when impact loads dominate, and stainless steel for pivot pins. The choice is confirmed during the free DFM review.
Can you machine a complete finger set rather than single parts? Yes. We machine housing, tip, pad, pin and bracket as one coordinated set on shared datums so the assembly stacks correctly without bench fitting.
What is the minimum order quantity? One piece. Prototype runs and series production use the same equipment, so a design that passes prototyping can move to volume without a process change.
How long does production take? Typically 5 to 15 working days after drawing approval, depending on the number of setups and surface treatments required.
Need Humanoid Robot Finger Parts? Get a Quote in 24 Hours.
Send your drawing (PDF, STEP or IGES). DFM feedback and quotation are free.
Request a Quote →